Precise manual control
Replace thumb joysticks with Hall-effect RC gimbals, then re-test sustained hover. This is the top priority, because it is what stopped us holding a hover.
Roadmap
Beta 1 proved the core. These upgrades are how AMD Labs moves it from research prototype toward the enterprise-level platform we set out to build.
Replace thumb joysticks with Hall-effect RC gimbals, then re-test sustained hover. This is the top priority, because it is what stopped us holding a hover.
Fly and document GPS position hold, return-to-launch and lawnmower survey missions, so that the code in the firmware becomes published results.
Move from breakout modules on a base PCB to a multi-layer board with the STM32H7, IMU and passives surface-mounted. Fewer connectors, less weight, less noise.
Replace 2.4 GHz radios with sub-GHz links such as LoRa or ExpressLRS, to go from about 100 m to several kilometres.
Move to fluxgate magnetometers or tuned induction coils, with digital signal processing to reduce false positives, plus proper validation tests.
Heavier sensors need a new propulsion set: lower KV motors, larger propellers and a higher-voltage battery.
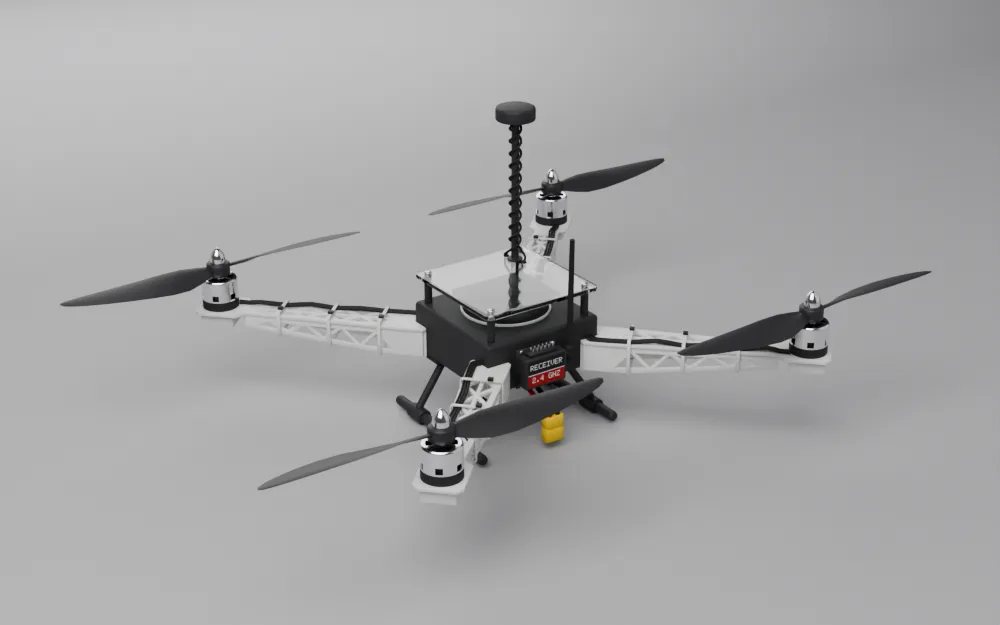 MoonLady Beta 1. 3D model for illustration.