Throttle
Controls altitude by motor speed
A low-budget drone built from scratch, including the flight controller, by a first-year team that started with no drone experience.
Our vision ↓
Exhibition
We are showing AMD24 and this website at FITExpo 2026. Come and talk to the team about how we built a drone from scratch, what went wrong, and where AMD Labs goes next.
Our vision
The intelligent, modular aerial infrastructure for an evolving world.
Our mission
Providing the adaptable aerial systems industries need to evolve and thrive.
Why we did this
We set out to make a low-budget drone at the enterprise level, and to build it from scratch, including the flight controller.
Our story began with our first-year microcontroller project. When we started, none of us knew anything about drones. We had a dream and a proposal, and we had to bring them into the real world.
Here you can learn about us and how we built it. We are Team MicroSolutions. After the project, we started an R&D startup called AMD Labs.
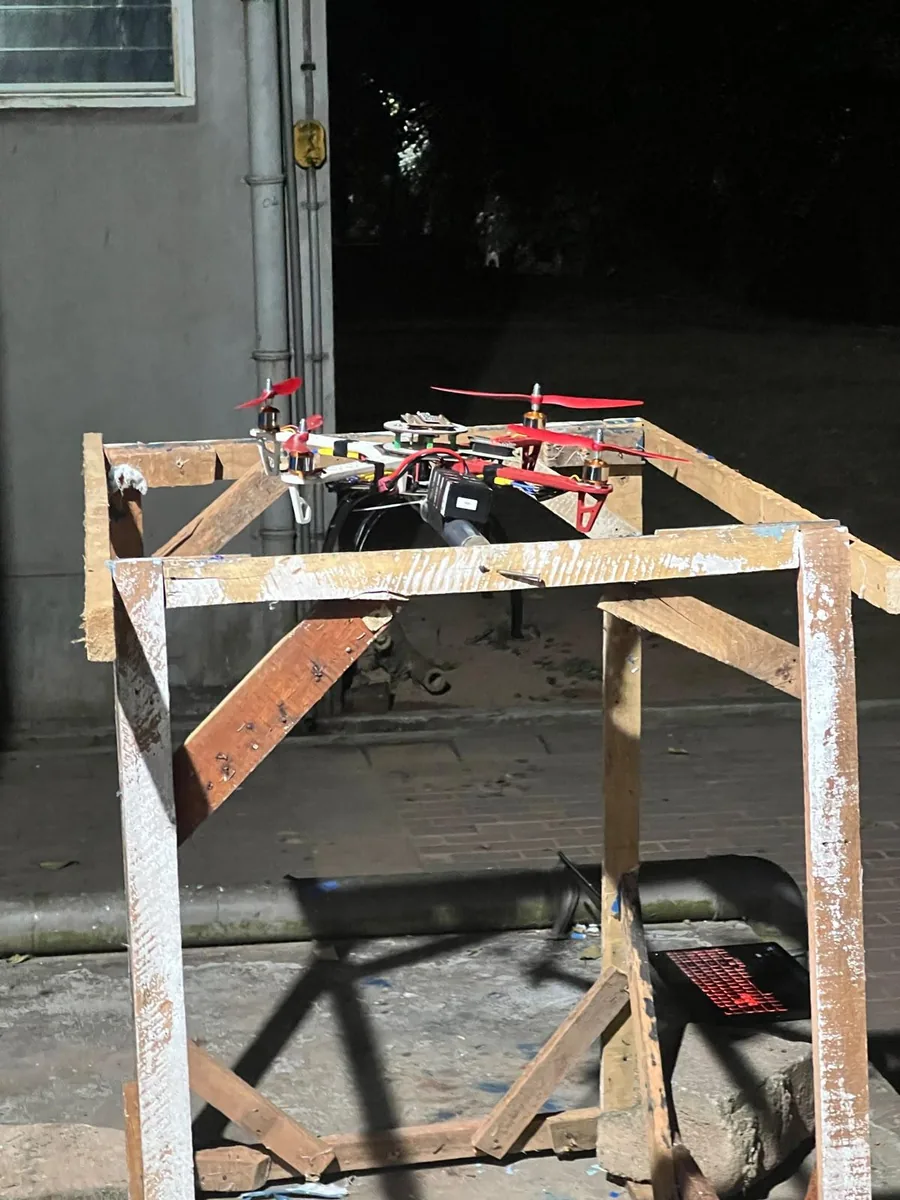
Start wherever you like. Everything we learned is here, including what went wrong.
MoonLady Beta 1
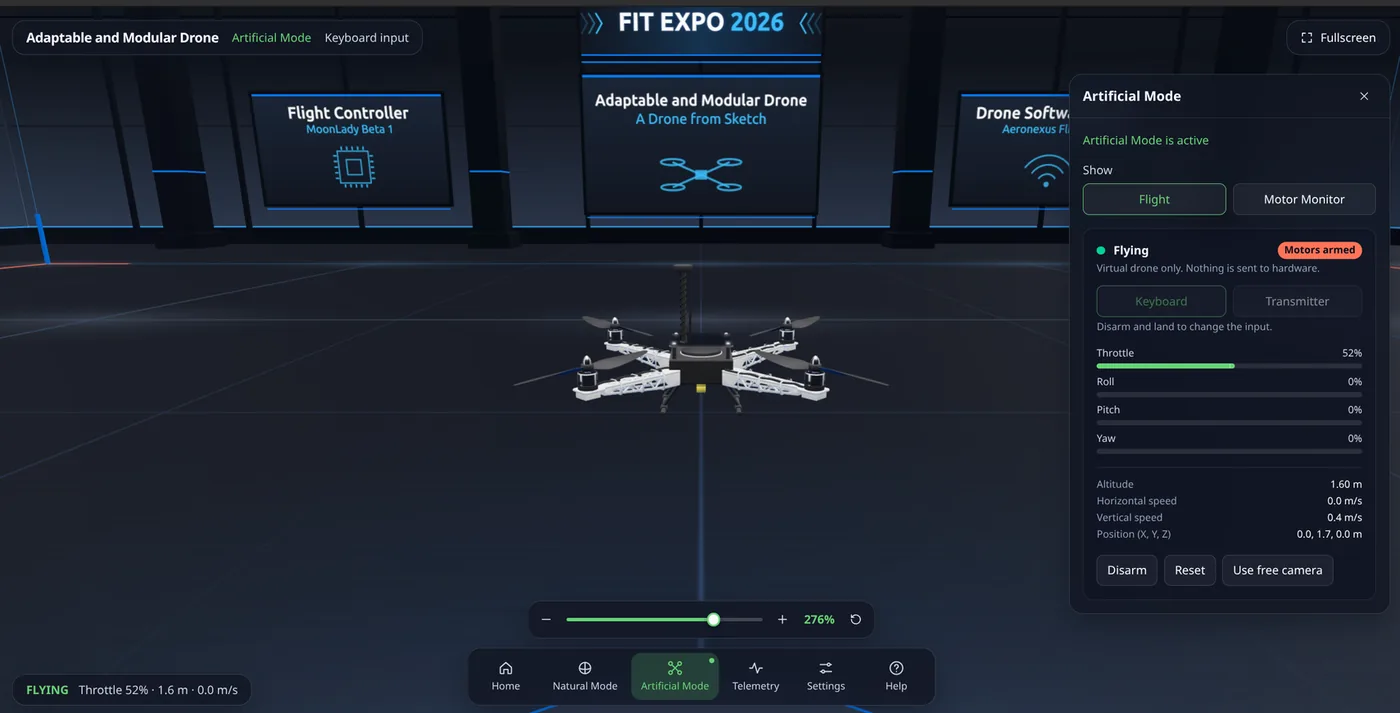
Drag to turn the 3D model. A custom flight controller built around an STM32H743 runs firmware we wrote ourselves. An ESP32 handles Wi-Fi, a second ESP32 runs our own transmitter, and a web dashboard shows it all live.
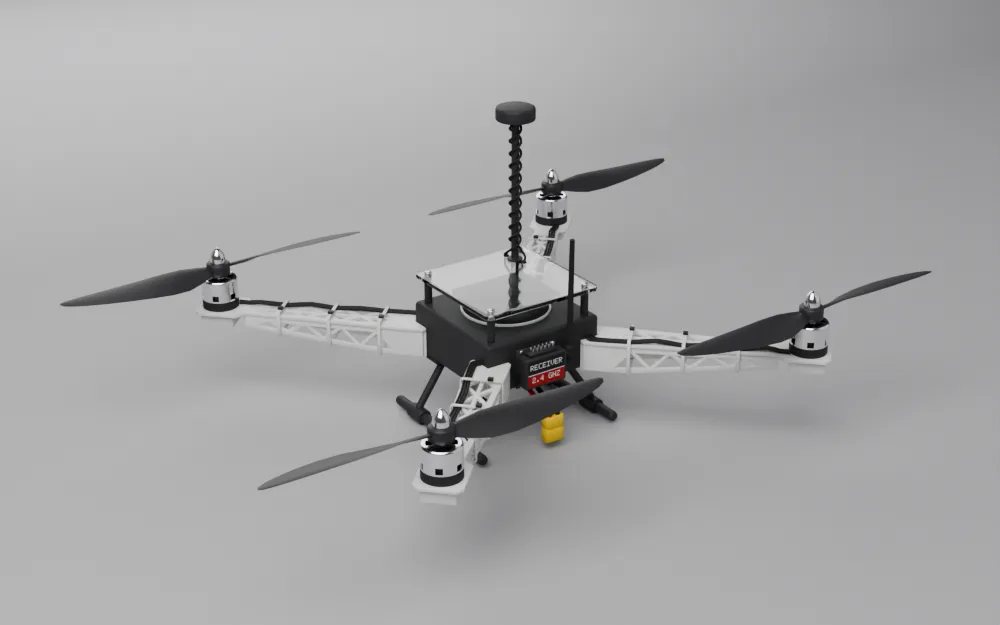 Drag to rotate. 3D model for illustration.
The Four Controls
Controls altitude by motor speed
Rotates drone nose in place
Tilts forward or backward direction
Moves sideways by motor speed
Real-time telemetry and pilot interface, built by our team and running in any web browser.
Honest status
This is a working research prototype and enterprise level is still our goal. We publish what works, what is limited and what still needs proving, because that is what helps the next builder.
Access tutorials and open-source code.
Explore step-by-step guides and project resources. This code opens our GitHub repository.